SURROUND VIEW SYSTEM
Description
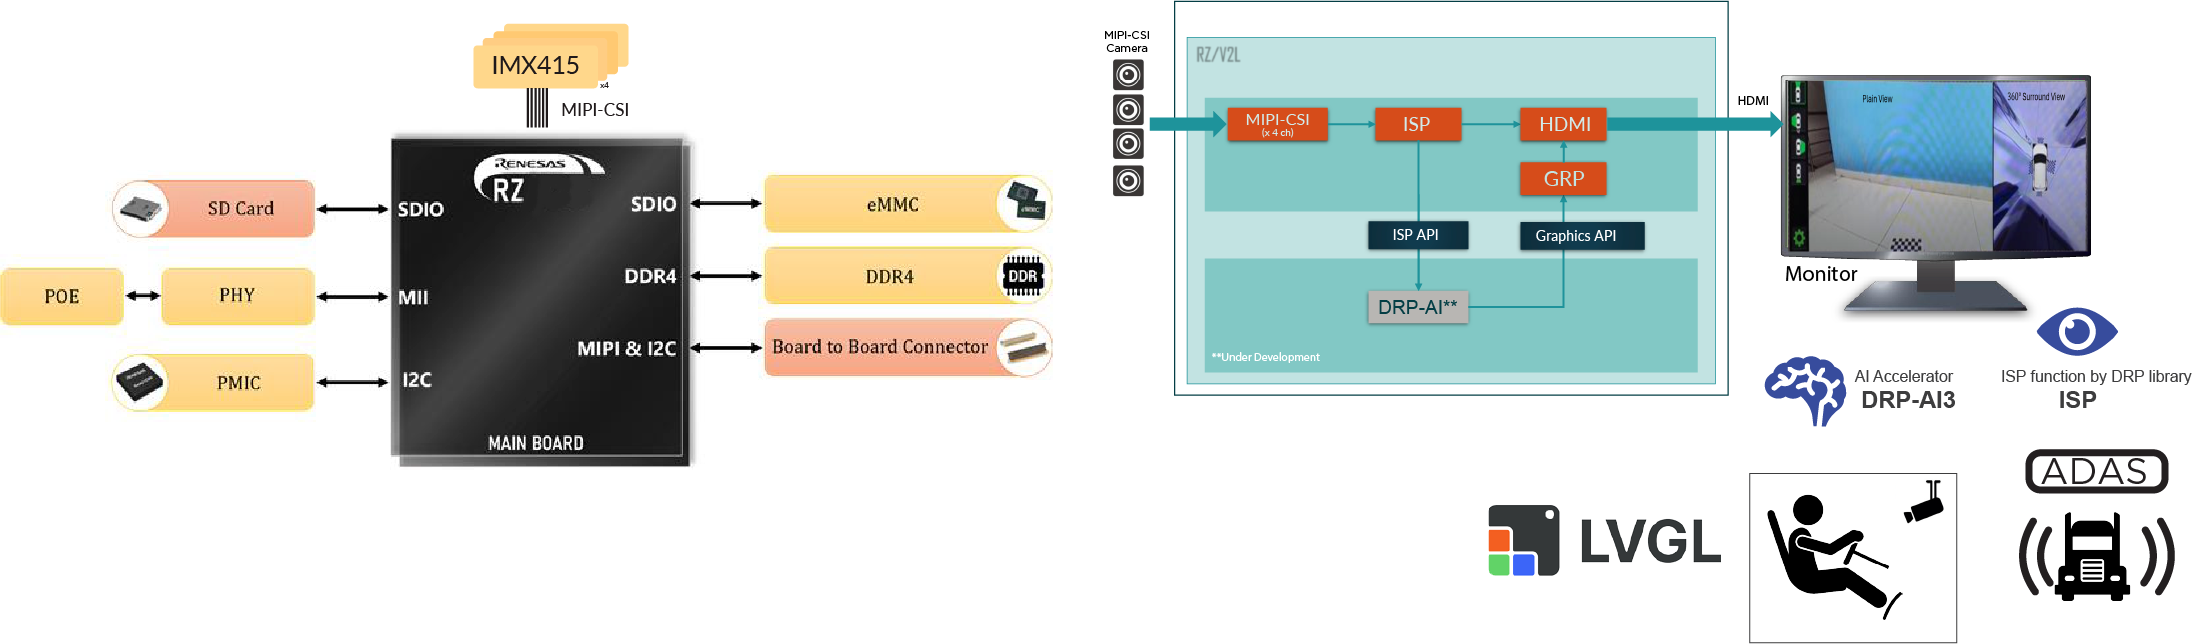
Surround View System (SVS) is a part of Advanced Driver Assistant System (ADAS) that provides a top-down video view of the surrounding environment. It helps to understand the relative position of the vehicle with respective surrounding environment through cameras in blind spots that are not recognised by the human visual system.
Features
- Provides the environment to the driver that can operate the vehicle easily and safely.
- Consists of 4 cameras mounted around the vehicle in different directions (Front-Rear, Left-Right).
- Combines the video images acquired by the cameras to provide a 360-degree (bird's-eye) view.
- ADAS (**Under development).
System Overview
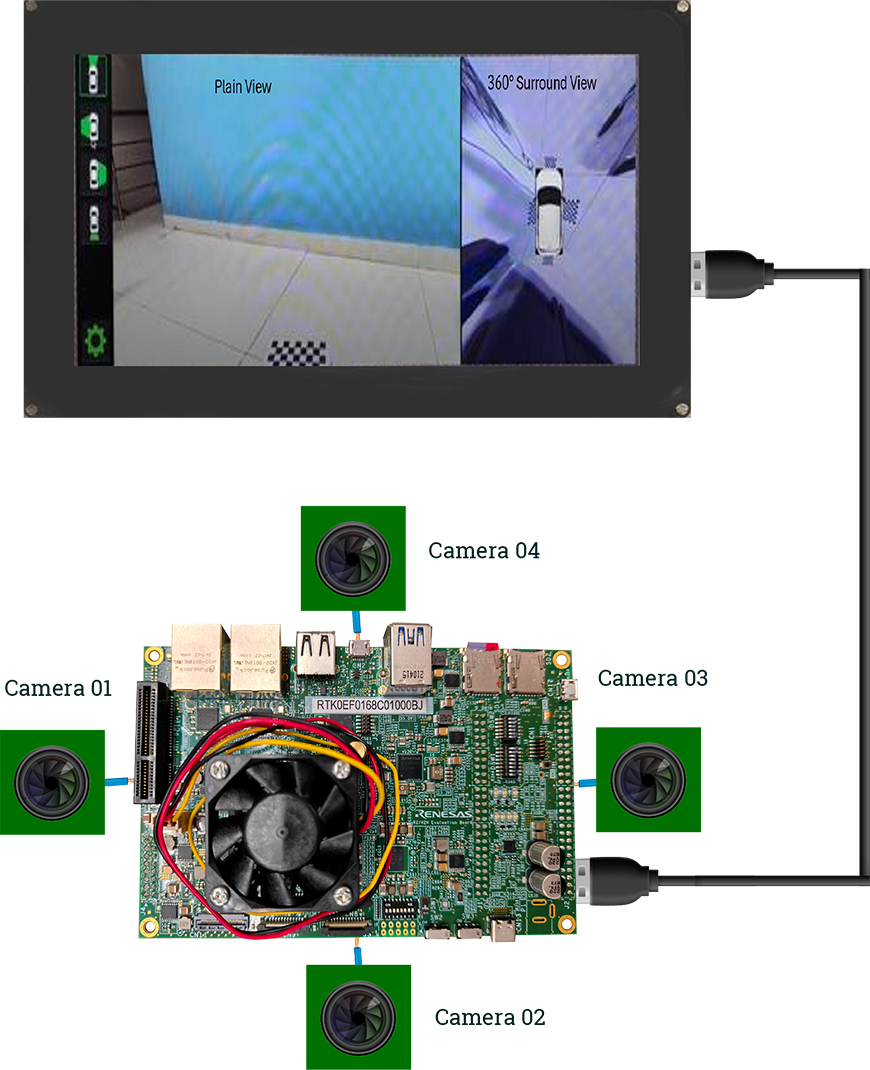
- Renesas RZ/V2H (Vision Series Platform) Quad-core Vision AI MPU with DRP-AI3 Accelerator and High-Performance Real-time Processor
- Cortex-A55 (1.8GHz) x 4 cores
- Cortex-R8 (800MHz) x 2 cores
- Cortex-M33 (200MHz) x 1 core
- AI Accelerator DRP-AI3 (8TOPS/dense, 80TOPS/sparse)
- Dynamically reconfigurable processor (DRP)
- Arm® Mali™-C55 ISP (option)
- 6MB on-chip SRAM
- LPDDR4/LPDDR4X memory interface
- Gigabit Ethernet 2ch
- USB 2.0 interface 2ch (On-the-Go (OTG) x 1ch, Host x 1ch)
- USB 3.2 (Gen2) interface 2ch (Host only) PCIe® interface (Gen3/4-lane) 1ch
- MIPI® CSI-2® camera interface 4ch
- CAN interface (CAN FD) 6ch
- Cameras - IMX415 Sensor Board 8MP / Rolling shutter (** other sensors also be supported)
Hardware Environment
- Host – Ubuntu 20/22.04 LTS
- Target
- Yocto SDK 3.x
- Linux kernel version 5.x
- LVGL-based GUI application
Applications
- ADAS for larger vehicles – Trucks, Tractor-Trailer, Cement Concrete Trucks
- Security and Surveillance
- Video conferencing